
Eye-hand Calibration Workflow
Eye-hand calibration establishes the relationship between the camera coordinate system and the robot coordinate system, allowing positions and orientations obtained through vision detection to be converted into the coordinate system used by the robot. Before starting calibration, use this page to confirm the complete workflow, camera mounting method, and calibration method.
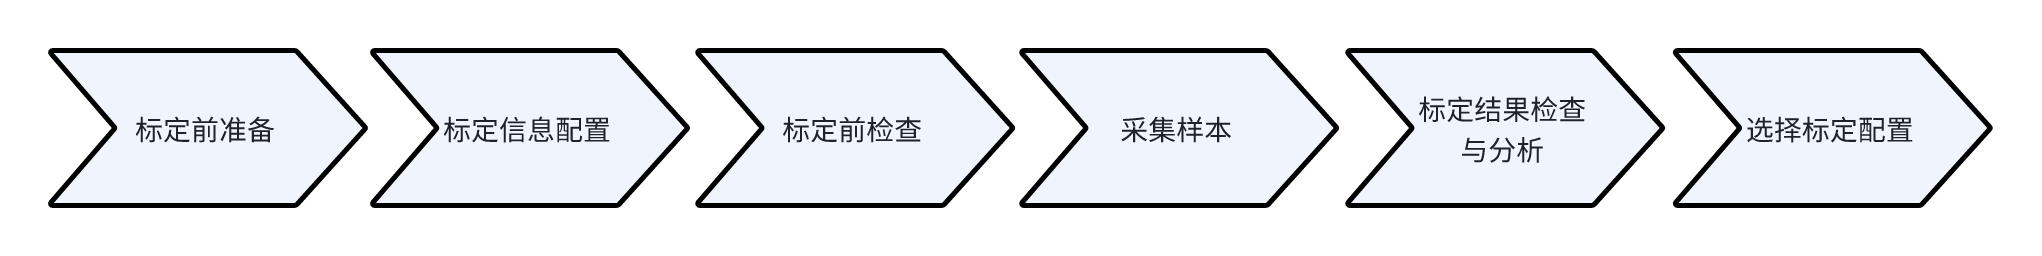
1. When Eye-hand Calibration Is Required
Eye-hand calibration is required when setting up a vision-guided system for the first time. Recalibrate after any of the following:
- The relative position between the camera and robot changes, such as when the camera is moved or reinstalled
- The camera is replaced
- The robot is replaced
2. Complete Calibration Workflow
- Complete the Pre-calibration Checks to confirm that the hardware, imaging, Calibration Board, and robot accuracy meet the requirements
- Open the Eye-hand Calibration page and click “Add Eye-hand Calibration”
- Configure the calibration name, calibration ID, camera, robot type, camera mounting method, Calibration Board, and calibration method
- Depending on the camera mounting method, proceed to Eye-in-hand Calibration or Eye-to-hand Calibration
- Collect valid samples using the selected method; six-axis automated setups can use Automatic Random Pose Sampling
- Complete sample collection and calculate the calibration result
- Follow Checking and Analyzing Calibration Results to check the error, sample distribution, and Point Cloud reprojection
- Once the result meets the project’s accuracy requirements, select this calibration configuration under “Run Configuration → Task Information → Eye-hand Calibration”
If any step does not meet the requirements, resolve the corresponding issue and repeat that stage. Do not use a calibration result that has not passed the checks.
3. Choose the Camera Mounting Method
| Mounting method | How to identify it | Setup for random pose sampling |
|---|---|---|
| Eye in hand | The camera is mounted on the robot end-effector and moves with the robot | The camera moves with the robot, and the Calibration Board is fixed to the work platform |
| Eye to hand | The camera is fixed outside the robot and does not move with it | The camera remains fixed, and the Calibration Board is mounted on the robot end-effector |
For needle-tip tool point-probing calibration, the Calibration Board is fixed to the work platform, and the needle-tip tool is mounted on the robot end-effector.
4. Choose the Calibration Method
| Robot type | Random pose sampling | Needle-tip tool point probing | Automatic random pose sampling |
|---|---|---|---|
| Three-axis robot | Do not use | Recommended | Not supported |
| Four-axis robot | Can be used if supported | Recommended | Not supported |
| Six-axis robot | Supported | Supported | Supported |
- Random pose sampling: Calculate the eye-hand relationship from Calibration Board samples at multiple positions and orientations
- Needle-tip tool point probing: Use the needle tip on the robot end-effector to touch the centers of the Calibration Board’s feature circles in sequence
- Automatic random pose sampling: The robot communication program receives the next sampling pose and completes closed-loop sample collection
5. Related Documents
| Document | When to use it |
|---|---|
| Pre-calibration Checks | Check the project, hardware, imaging, Calibration Board, and robot accuracy before sampling |
| Eye-in-hand Calibration | The camera is mounted on the robot end-effector |
| Eye-to-hand Calibration | The camera is fixed outside the robot |
| Checking and Analyzing Calibration Results | Determine whether the result is usable after calculation |
| Automatic Random Pose Sampling | A six-axis robot collects samples automatically through a communication program |
| Disable Calibration Sample Similarity Validation | The range of motion is limited and sample similarity warnings appear repeatedly |
| Common Issues and FAQ | Troubleshoot camera accuracy, imaging, robot accuracy, and calibration error |
6. Completion Criteria
The eye-hand calibration workflow is complete only when all of the following conditions are met:
- All pre-calibration checks have passed
- The number and distribution of valid samples meet the requirements of the selected calibration method
- Calibration diagnostics and on-site coordinate verification meet the project’s accuracy requirements
- The newly generated eye-hand calibration configuration has been selected in Run Configuration