
Point Cloud Noise Filtering User Guide
The Point Cloud noise filtering function is used to filter the Point Cloud noise of instances, provide more accurate instance bounding boxes and instance depths, and facilitate instance Z-value sorting. This article mainly introduces how to adjust the relevant Parameters after turning on Point Cloud noise filtering.
1. Operation Guide
Applicable Scenes: Loading and unloading of neatly arranged general type target objects; loading and unloading of neatly arranged plane type target objects; loading and unloading of neatly arranged plane type target objects (Parallel); loading and unloading of neatly arranged plane type target objects (Image Matching); loading and unloading of Circle type target objects; loading and unloading of Cylinder type target objects; and loading and unloading of Quadrilateral type target objects.
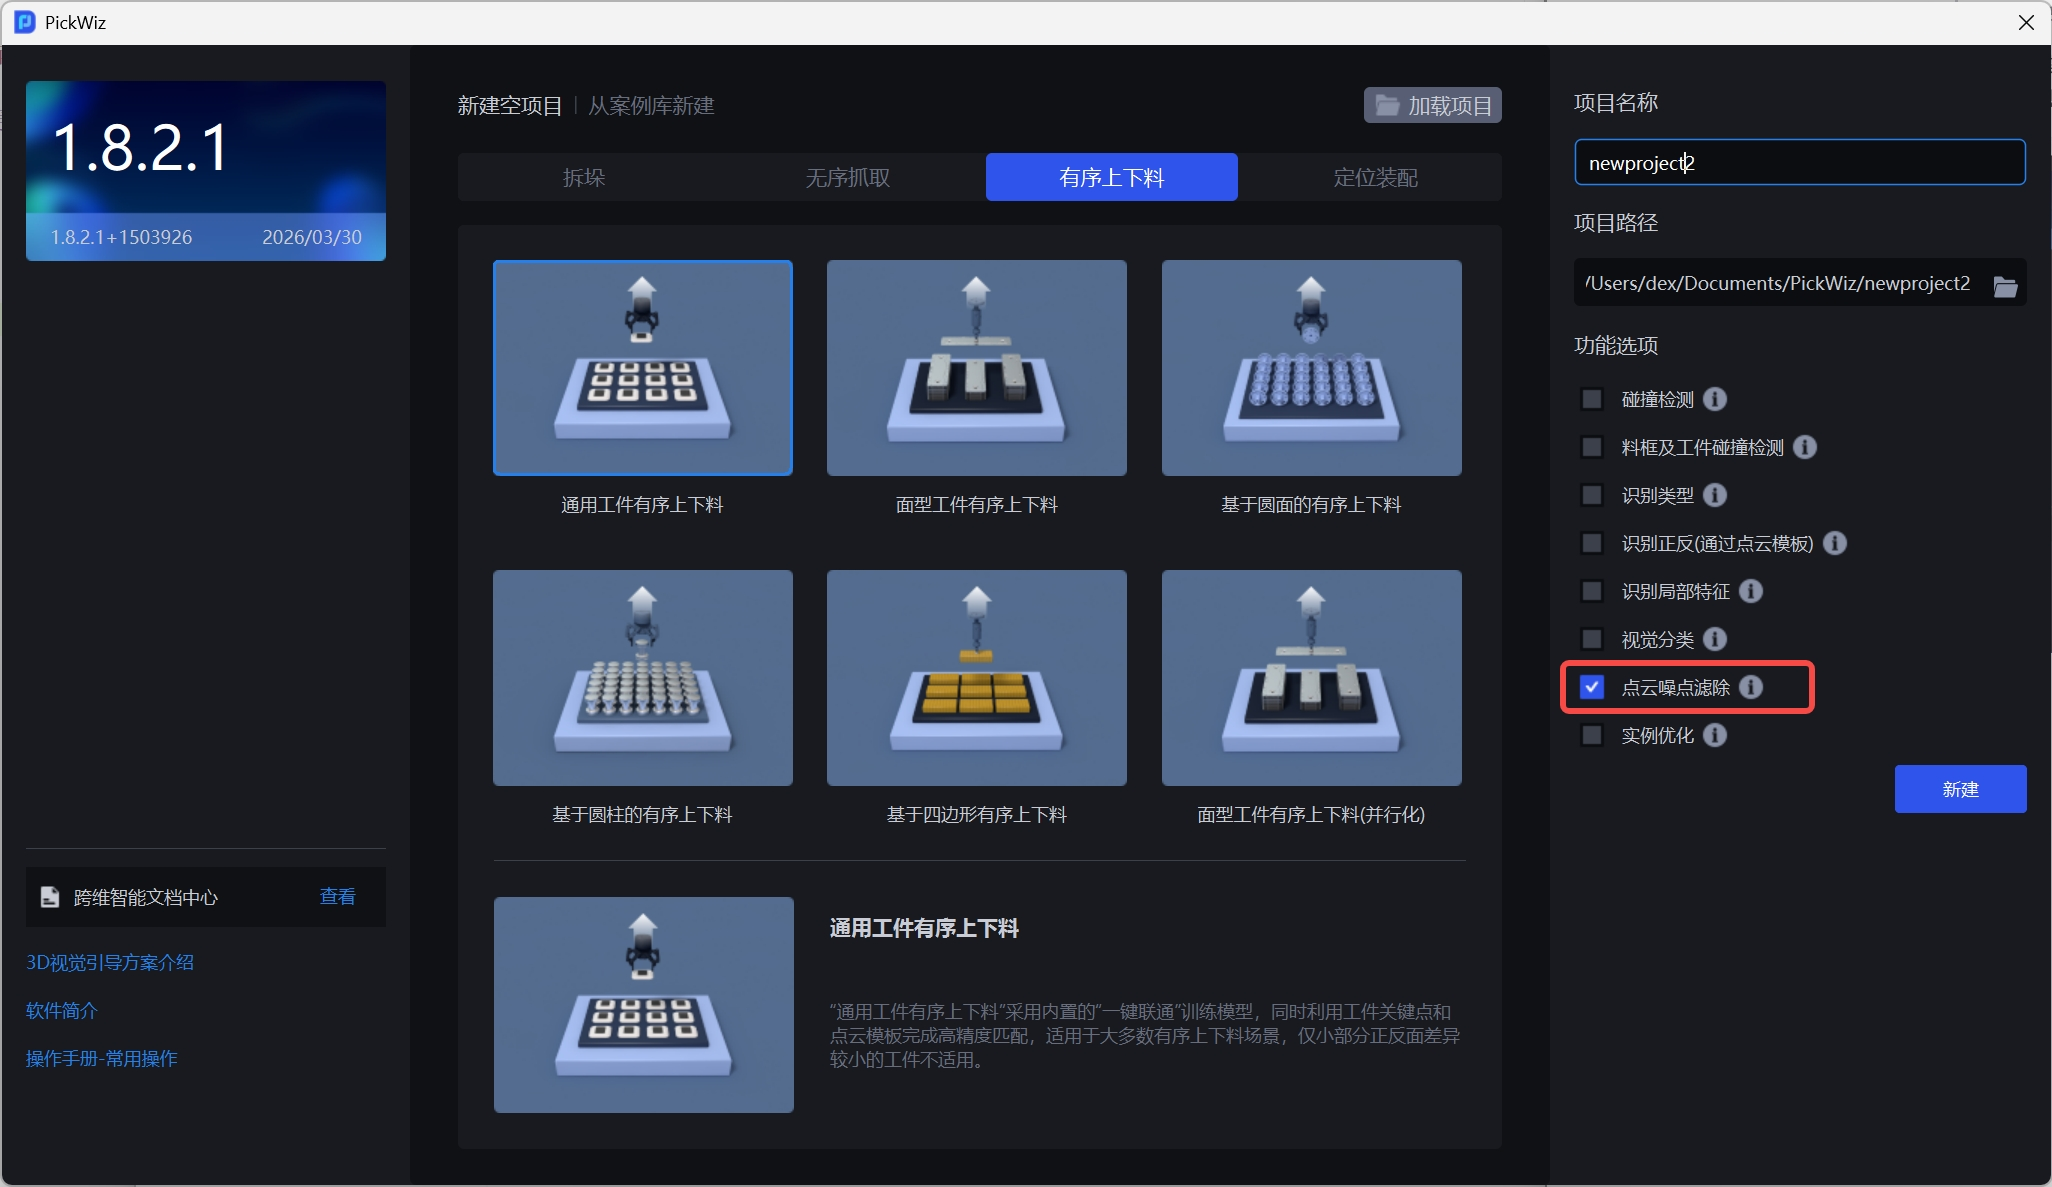
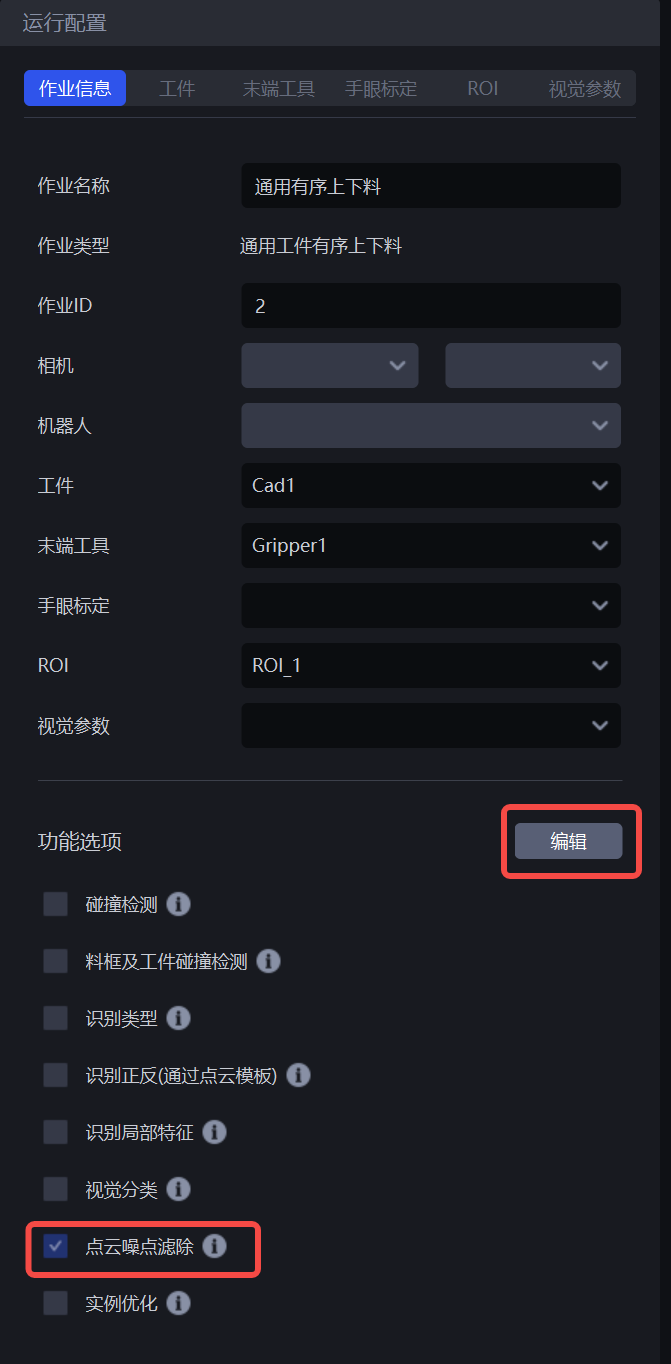
- When creating a new project, check the Point Cloud noise filtering function in the function options on the right; if it is not checked when creating a new project, click Edit on the Task information interface, check Point Cloud noise filtering and save it.
2. Parameter adjustment guide
In the visual Parameter interface, the configuration item for Point Cloud noise filtering will appear.
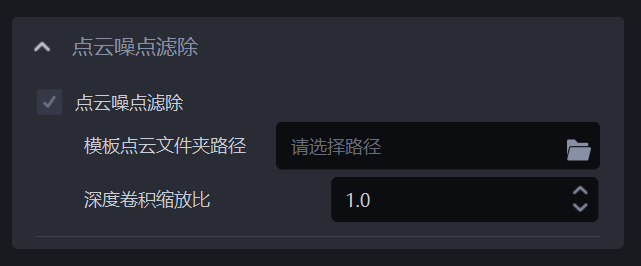
Template Point Cloud Folder Path
- You need to specify the path of the template Point Cloud. The template Point Cloud is generally obtained from ScenePoint Cloud. You can refer to Point Cloud Template Production Guide
Depth convolution scaling ratio
- Adjusts the resolution of the image and template. Adjustment is generally unnecessary; use the default value of 1.0. For the depth convolution scale ratio, a smaller value yields fewer points in the downsampled point cloud and speeds up vision computation, but may reduce accuracy. A larger value has the opposite effect. Range: [0.1,1.0].